01 / REAL
Natural behavior
Unscripted environments and authentic task execution—not staged studio simulations.
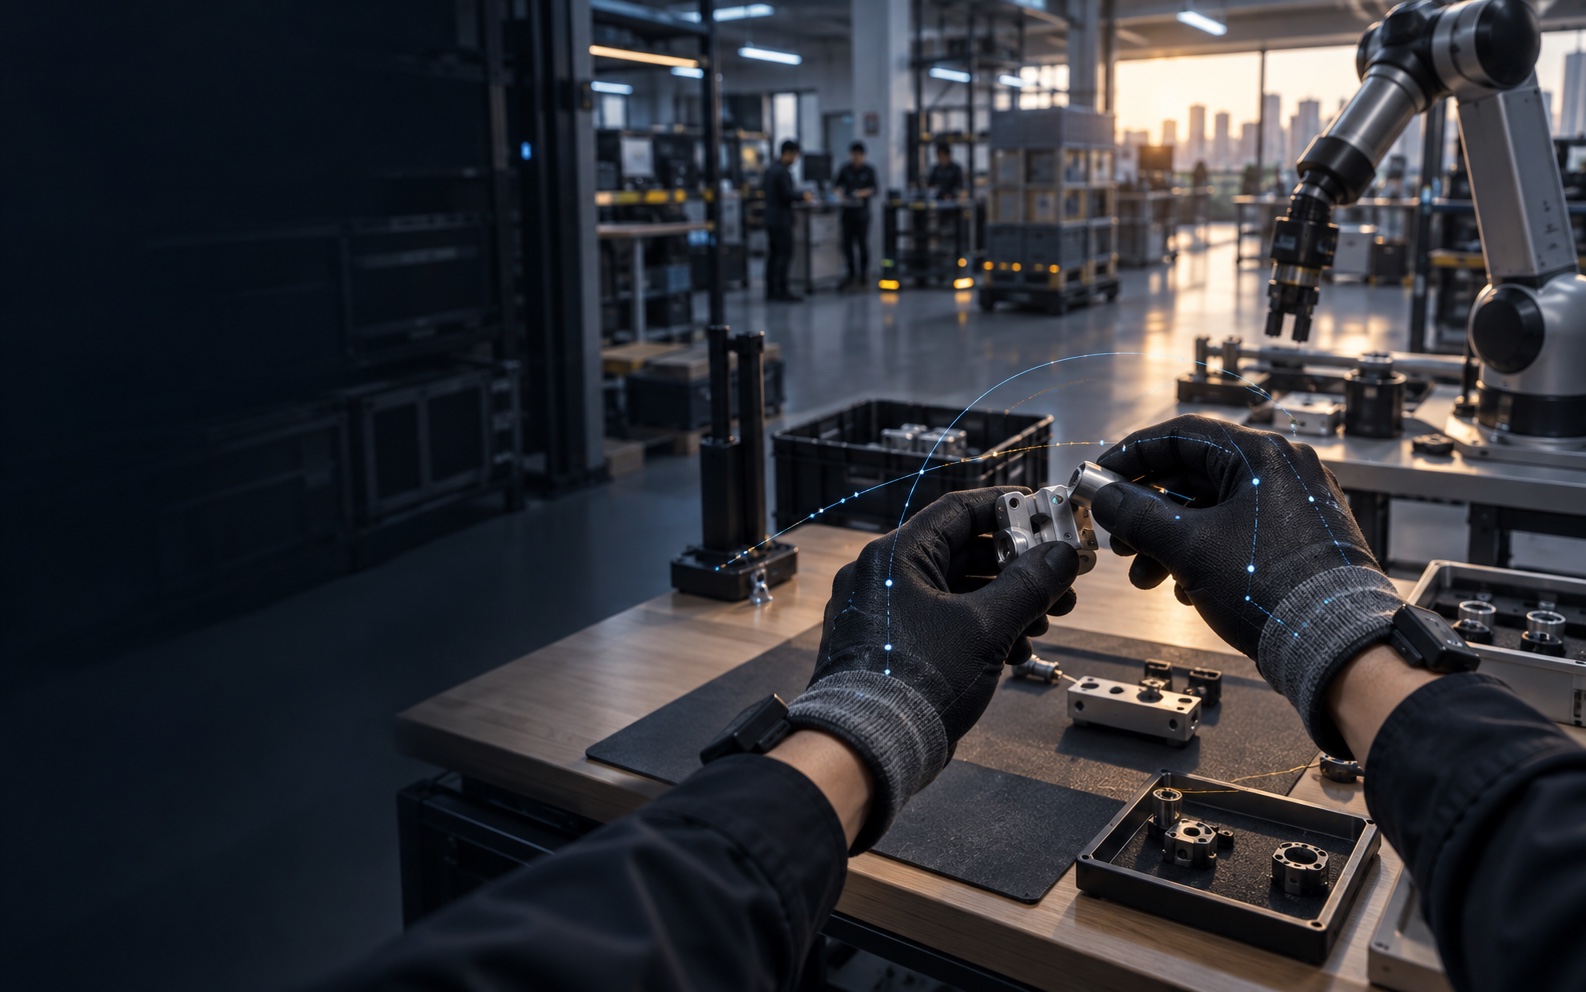
RoboBase captures high-quality human demonstrations across real homes, factories, warehouses and workplaces in China—built to train machines that act in the real world.
Physical intelligence requires seeing how people actually interact with objects, tools and environments. We turn real-world human activity into model-ready datasets—with the scale, diversity and operational rigor that frontier robotics teams need.
How collection works →Unscripted environments and authentic task execution—not staged studio simulations.
Objects, operators, layouts, lighting and edge cases sampled across locations.
Video, pose, motion and task metadata synchronized into a coherent record.
Consent-led collection, traceable QA and delivery to your exact schema.
Choose one modality or combine synchronized streams around a precise task definition.
First-person demonstrations of manipulation, assembly, household and operational tasks in real environments.
Structured motion data for understanding contact, intent and fine-grained action.
Robot-ready demonstrations collected with portable interfaces and controlled task protocols.
A collection stack designed around your target behavior, sensors, ontology and evaluation needs.
Start small, inspect real samples, then scale only after the task definition and data quality are proven.
We translate your model objective into collection instructions, edge cases, sensors and acceptance criteria.
A small, representative sample validates feasibility, schema and signal quality before scale-up.
Your team inspects raw and processed data. We refine protocols using concrete feedback.
Distributed collection expands under calibrated checks, audit trails and defined delivery milestones.
Structured, versioned datasets arrive in your schema with metadata and quality reports.
Access varied homes, factories, warehouses, workshops and commercial spaces through a locally managed collection network. One partner, from field operations through final delivery.
Share the behavior you want a model or robot to learn. We will shape a focused pilot with representative samples, a clear QA plan and a practical path to scale.
Request a pilot ↗Typical first step: a scoped sample collection and schema review.